|
|
|
|
|
|
|
|
Paper (Coming Soon) |
Code (Coming Soon) |
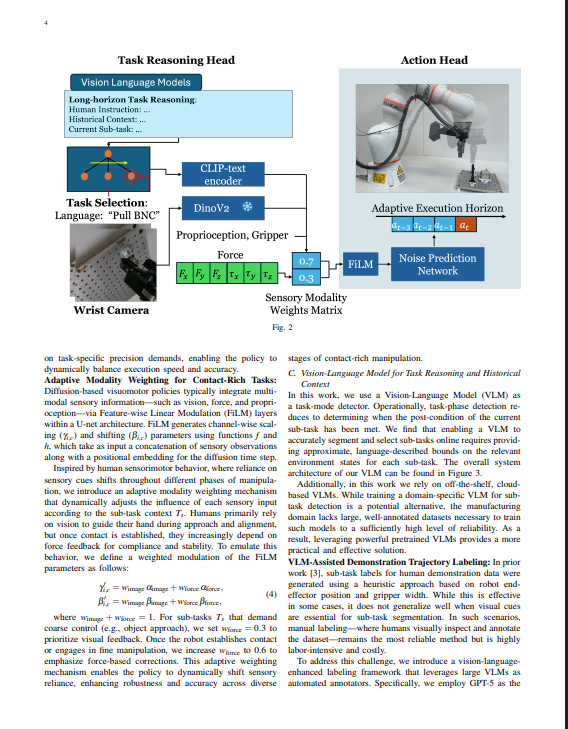
Real-world robotic disassembly requires long-horizon execution, where robots must perform ordered sequences of manipulation tasks across multiple parts within a single scene. Multiple valid task goals and diverse assembly configurations make it difficult for imitation policies to infer the intended skill from raw observations alone, particularly when training data cannot cover the combinatorial diversity of real-world configurations and part geometries. We show that incorporating task context through language alleviates these challenges by providing explicit structure for skill selection and associating language-specified tasks with their corresponding manipulation targets in the visual scene. The proposed framework combines hierarchical task selection with task-context-aware imitation learning to ground language instructions in spatial visual representations for robotic disassembly. The resulting framework generalizes across diverse connector geometries and assembly configurations without requiring explicit object annotations. Our method improves end-to-end task success by 35 percentage points over the baseline diffusion policy and by 75 percentage points over the previous task-context-aware baseline.
D-Sub Removal
USB Removal
BNC Removal
Terminal Block Removal
End-to-End Removal
D-Sub Freezing during Grasp
BNC Freezing during Grasp
Terminal Block Freezing during Grasp
Terminal Block Freezing during Pull
USB Freezing during Grasp
USB Freezing during Pull
USB Freezing End-to-End
Double D-Sub Removal
Double USB Removal
Double Terminal Block Removal
Double BNC Removal
NEMA 5-15P 120V Power Cable
Velcro
Industrial-Grade Magnet
USB Hub
BNC Type A
BNC Type B
D-Sub Type B
Blue USB
Orange USB
Silver USB
USB Type A
| Item Number | Description | Manufacturer | MPN | Quantity | Preview |
|---|---|---|---|---|---|
| 1 | D-Sub Interface Mount | 3D Printed | D_sub_interface.STL | 2 |
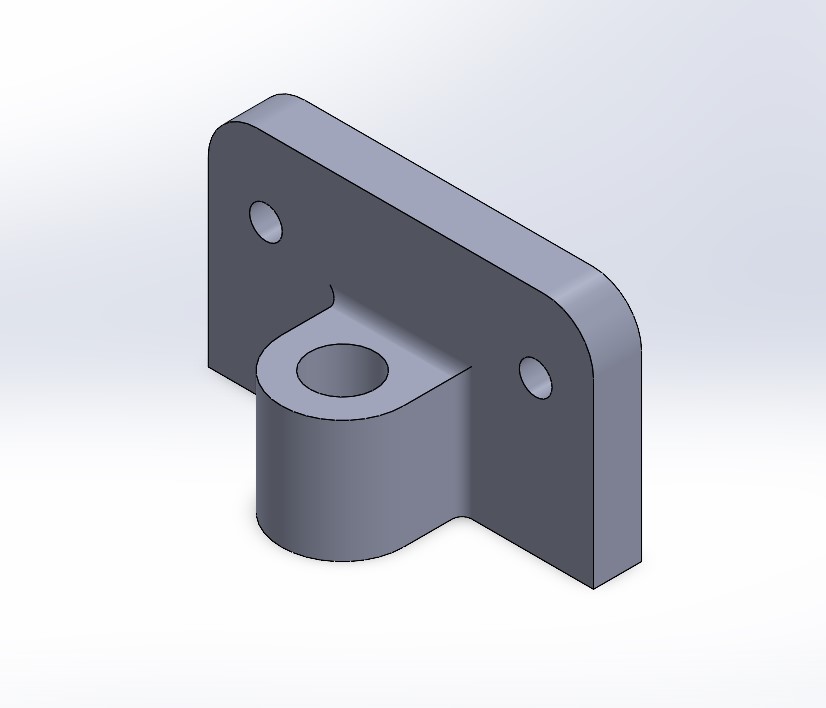
D-Sub Interface Mount
|
| 2 | USB Interface Mount | 3D Printed | usb_interface.STL | 1 |
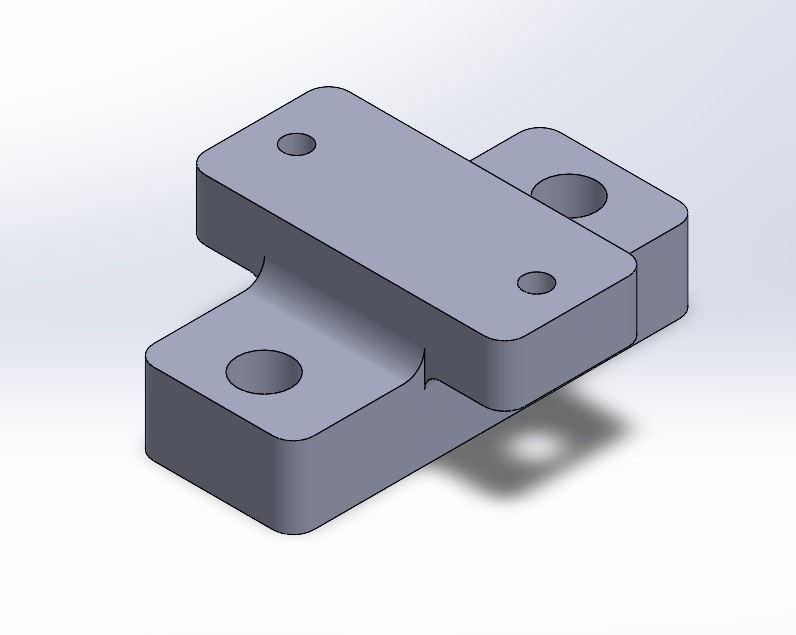
USB Interface Mount
|
| 3 | BNC Interface Mount | 3D Printed | bnc_interface.STL | 1 |
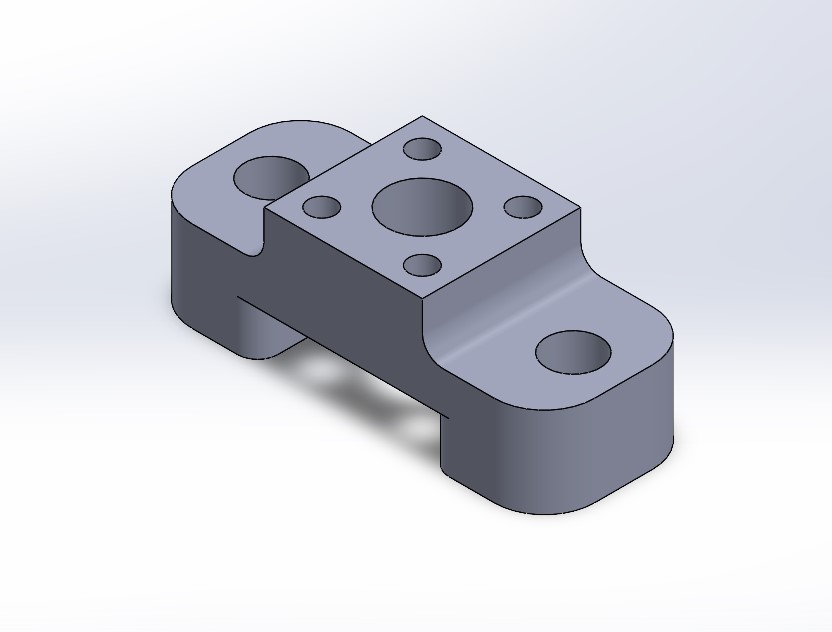
BNC Interface Mount
|
| 4 | Terminal Block Interface Mount | 3D Printed | terminal_block_interface.STL | 1 |
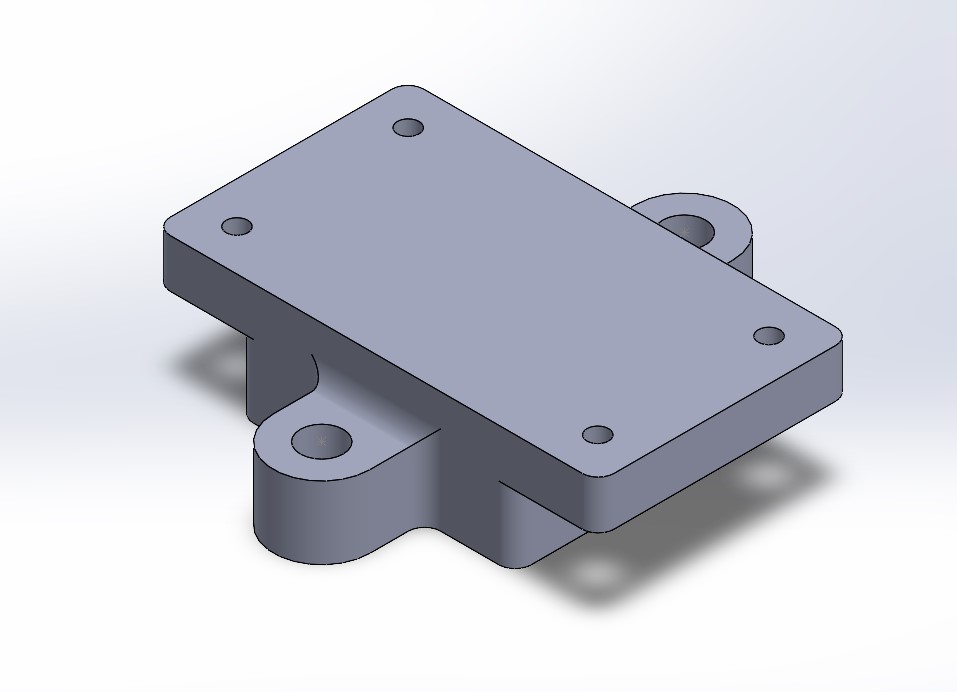
Terminal Block Interface Mount
|
| 5 | Plate Standoff, 1" | 3D Printed | standoff.STL | 4 |
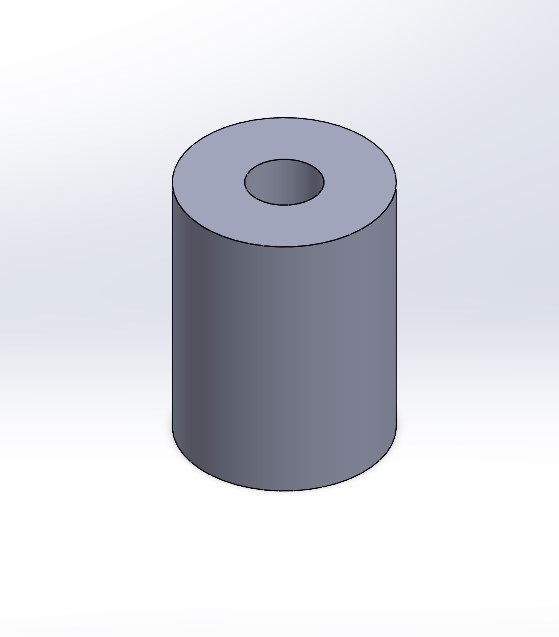
Plate Standoff, 1"
|
| 6 | D-Sub, Backshell | JAE Electronics | DB-C8-J10-B5-1R | 2 |
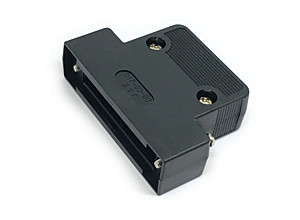
D-Sub Backshell
|
| 7 | D-Sub, Male | NorComp Inc. | 171-025-103L001 | 1 |
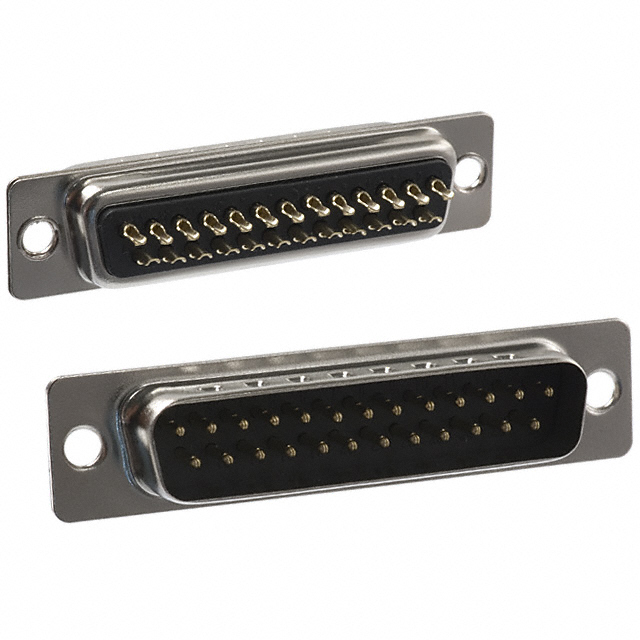
D-Sub Male
|
| 8 | D-Sub, Female | TE Connectivity AMP | 207463-1 | 1 |
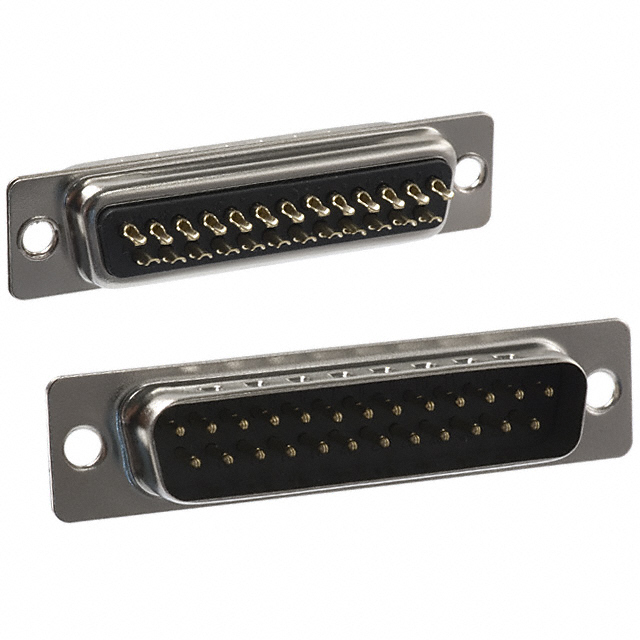
D-Sub Female
|
| 9 | USB Connector, Male | MISUMI | U02-AM-BM-0.5 | 1 |
USB Connector, Male
|
| 10 | USB Passthrough, Panel Mount, Female | MISUMI | U09-AF-AF-B | 1 |
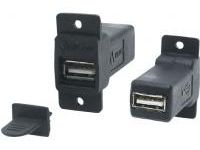
USB Passthrough, Panel Mount
|
| 11 | BNC, Male | RF Solutions | ADP-SMBM-BNCM | 1 |
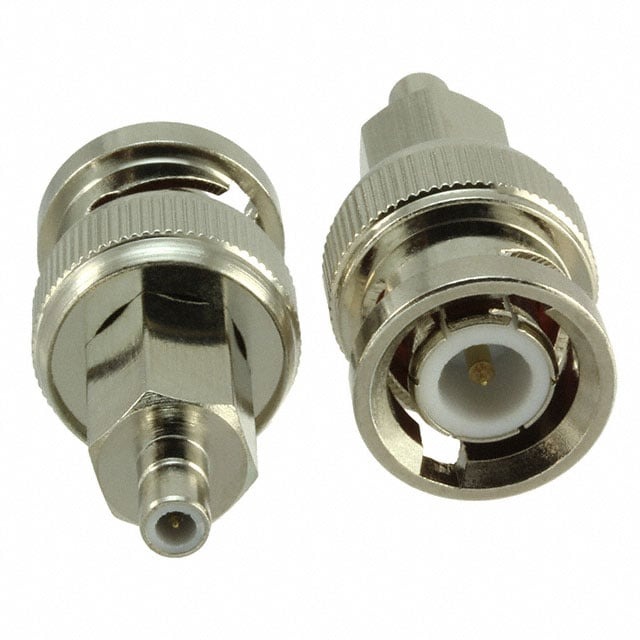
BNC Male
|
| 12 | BNC, Female | Pomona Electronics | 2451A | 1 |
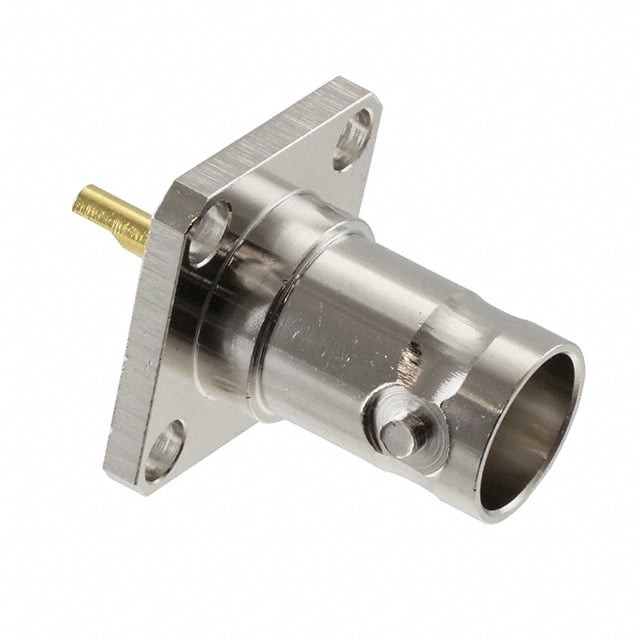
BNC Female
|
| 13 | Terminal Block, Male | MISUMI | MCON-E10-SP | 1 |
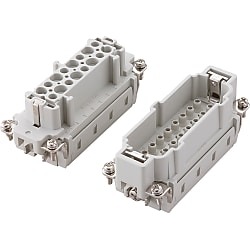
Terminal Block, Male
|
| 14 | Terminal Block, Female | MISUMI | MCON-E10-SS | 1 |
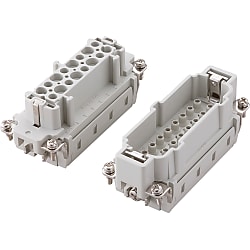
Terminal Block, Female
|
| 15 | Fixture Plate, 10×10×1/2", 1/4"-20 Thread | JMSMSH | 10" x 10" x 1/2" | 1 |
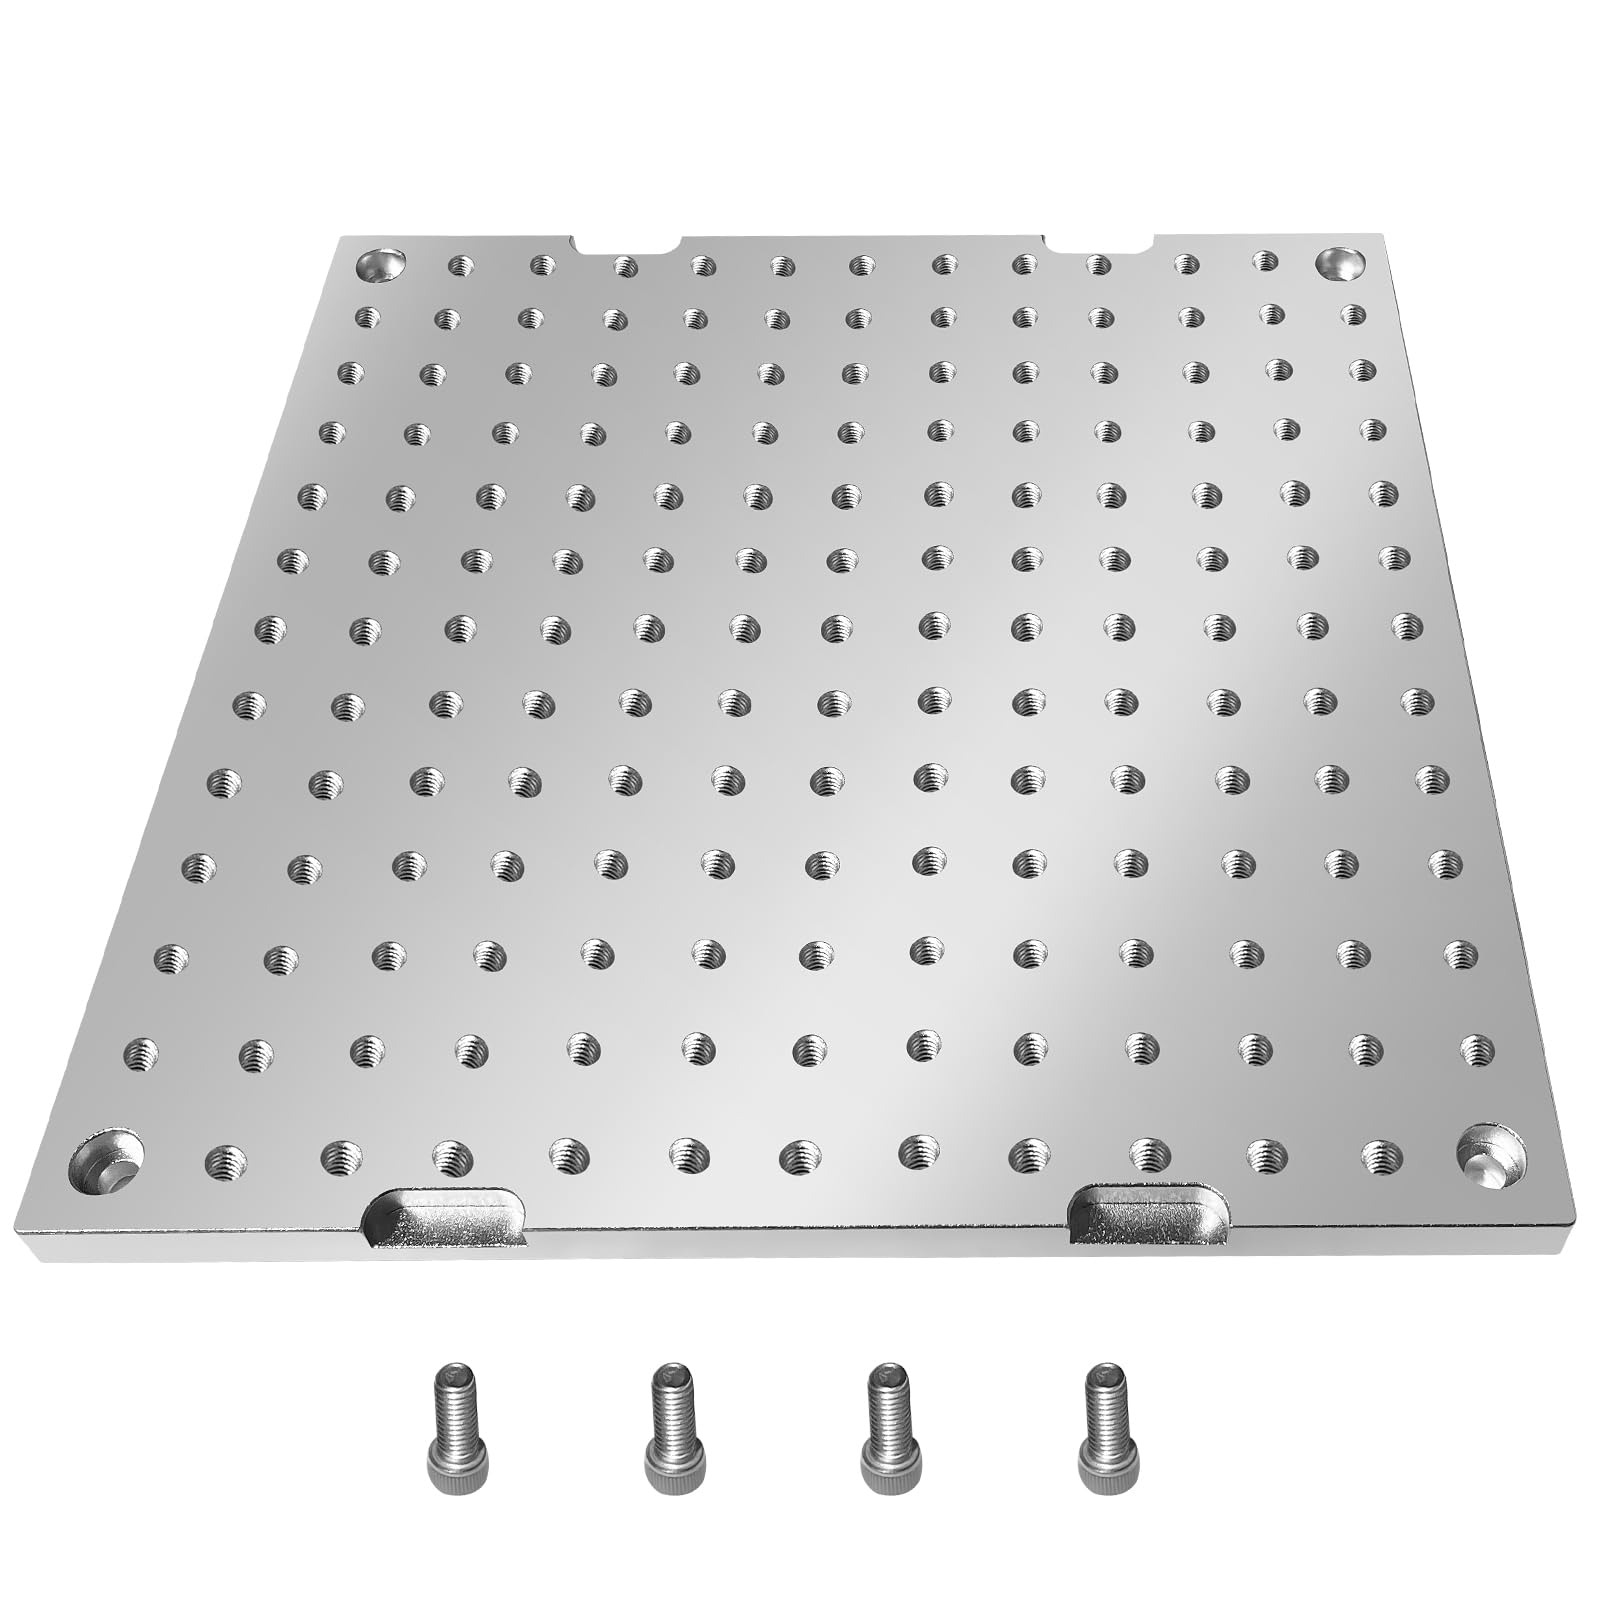
Fixture Plate
|
| 16 | Screw, Socket Head, 1/4"-20, 0.75" L | McMaster-Carr | 92196A540 | 8 |
1/4"-20 Socket Head Screw
|
| 17 | Screw, Socket Head, M3, 35mm L | McMaster-Carr | 91290A135 | 6 |
M3 Socket Head Screw (35mm)
|
| 18 | Screw, Socket Head, M3, 16mm L | McMaster-Carr | 91290A120 | 6 |
M3 Socket Head Screw (16mm)
|
| 19 | Nut, Hex, Thin, M3 | McMaster-Carr | 90695A033 | 12 |
M3 Thin Hex Nut
|
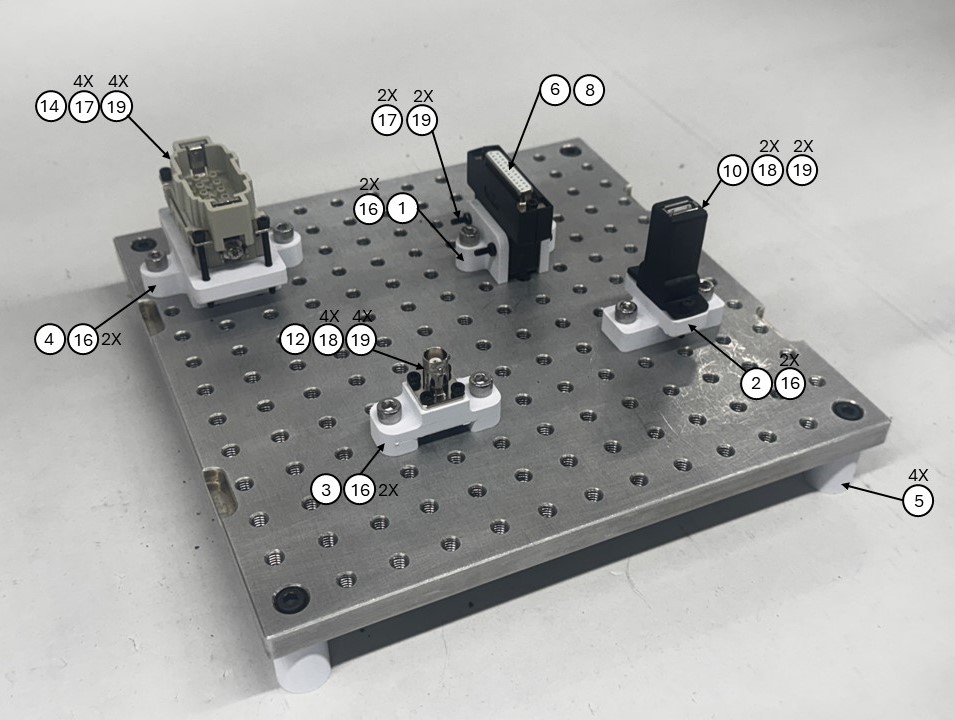
Full Task Board (dissambled)
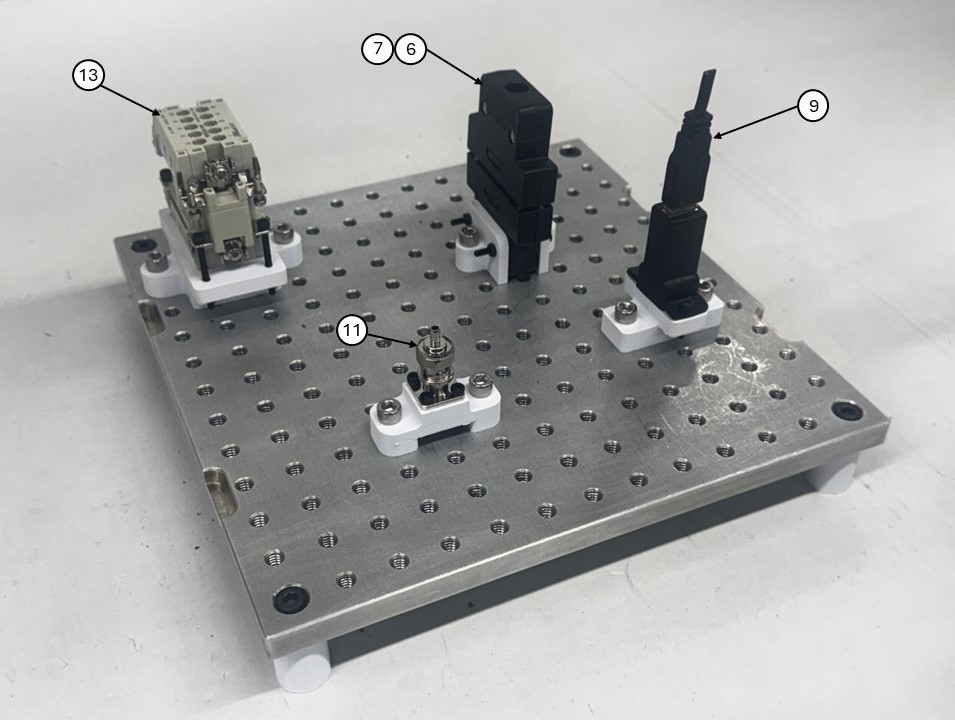
Full Task Board (assembled)
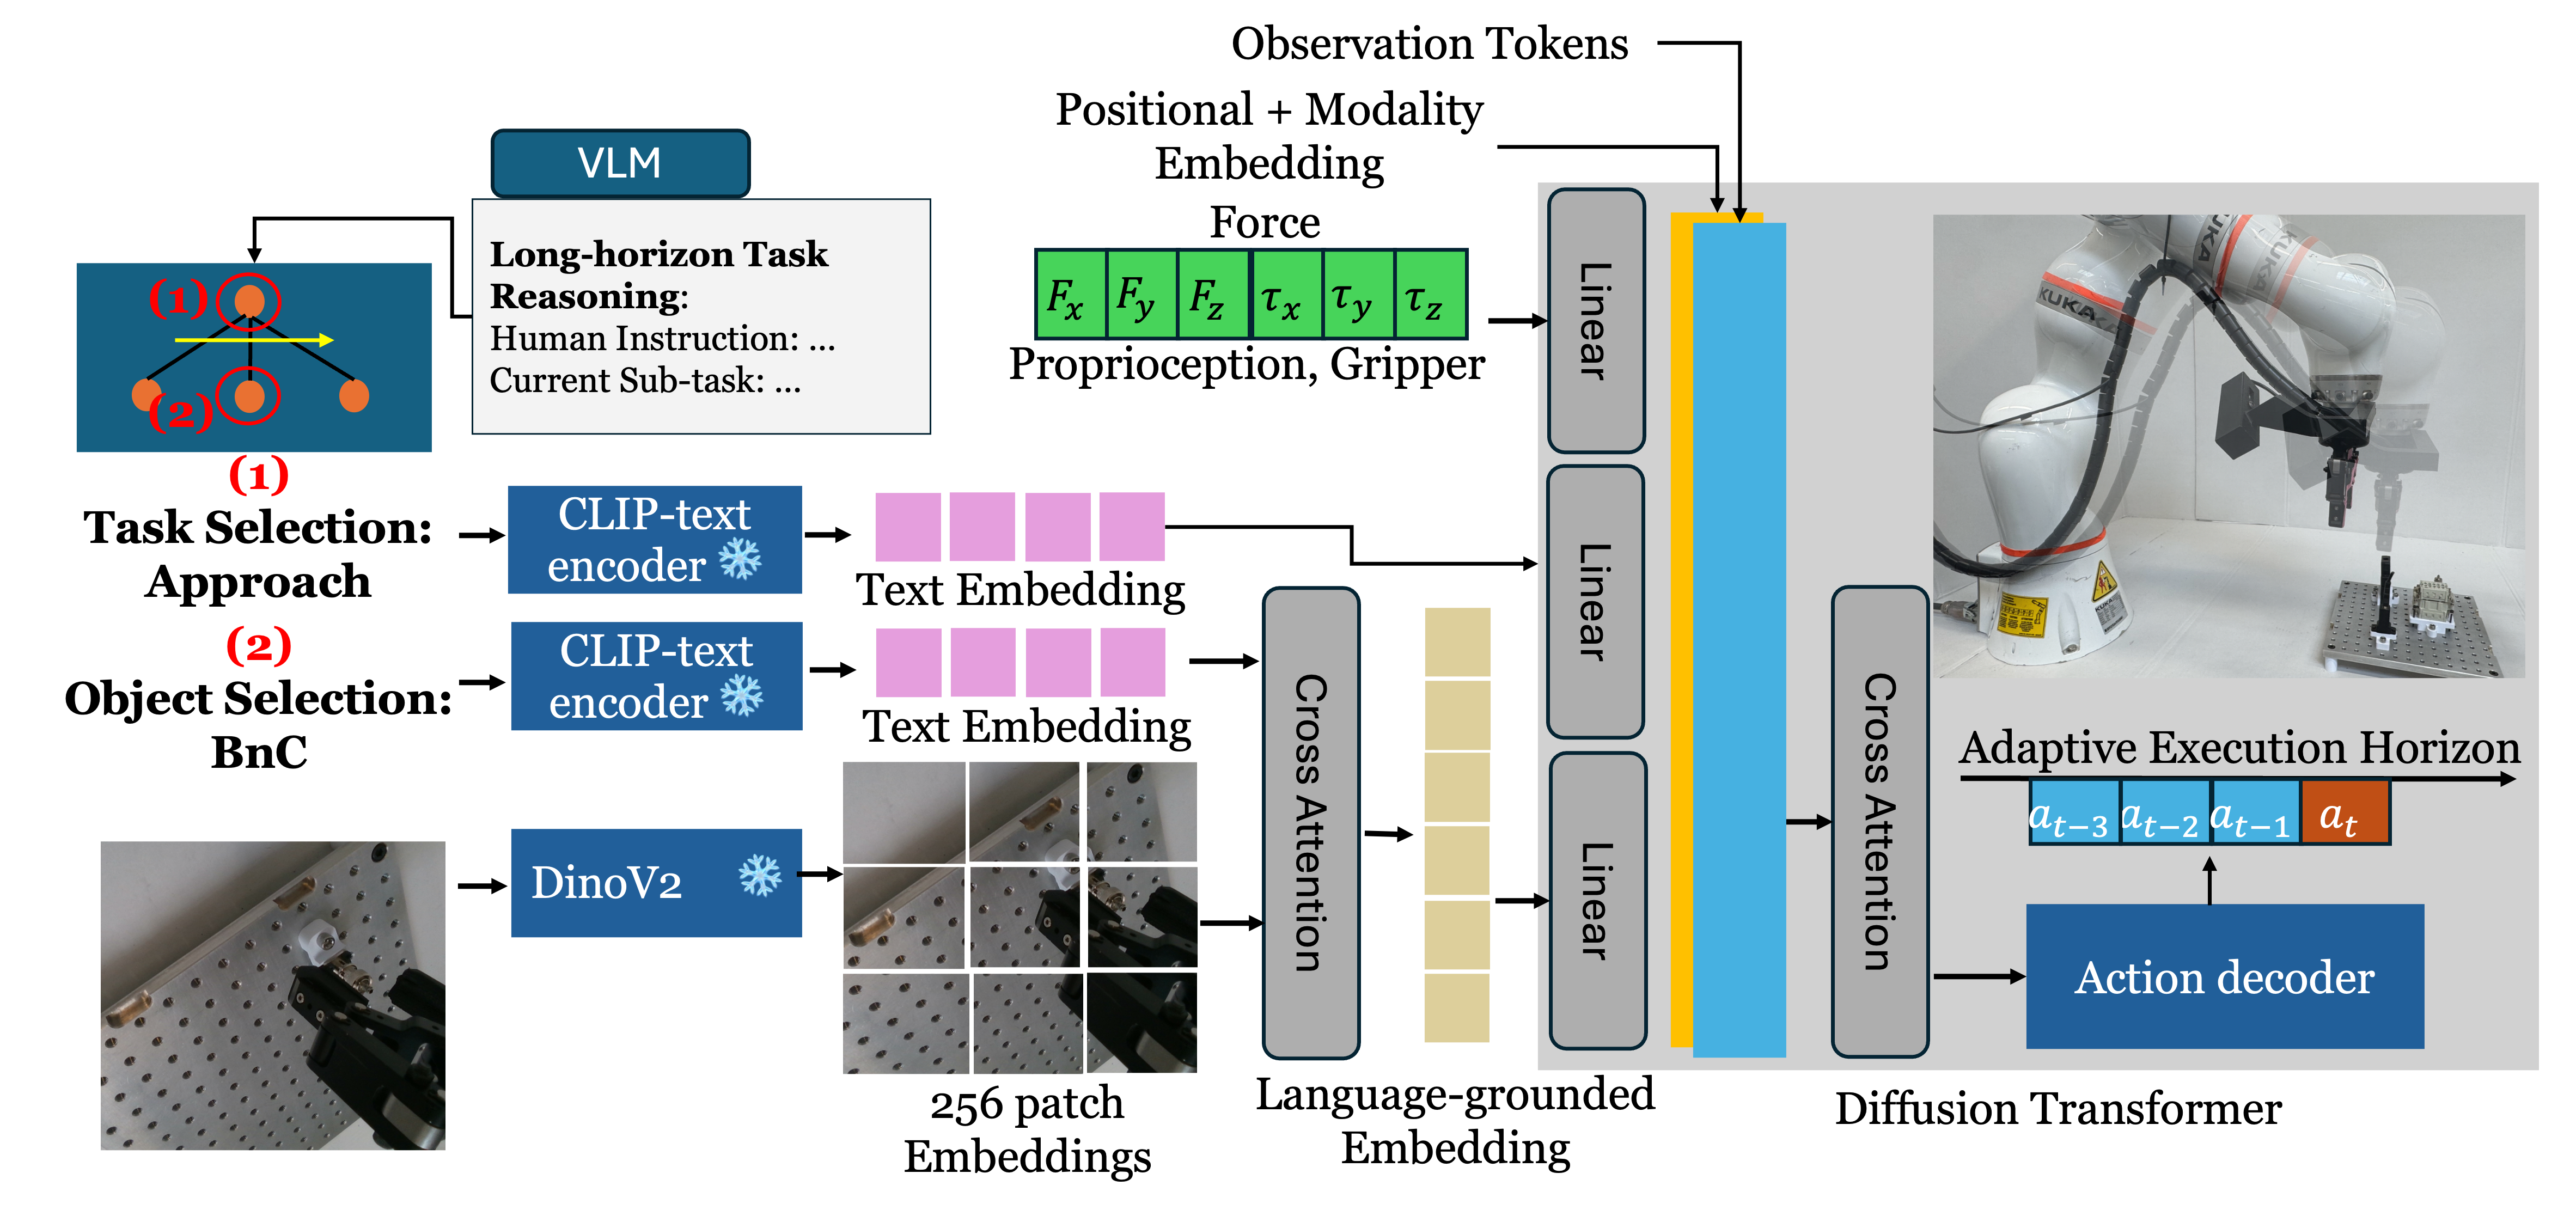
System Architecture
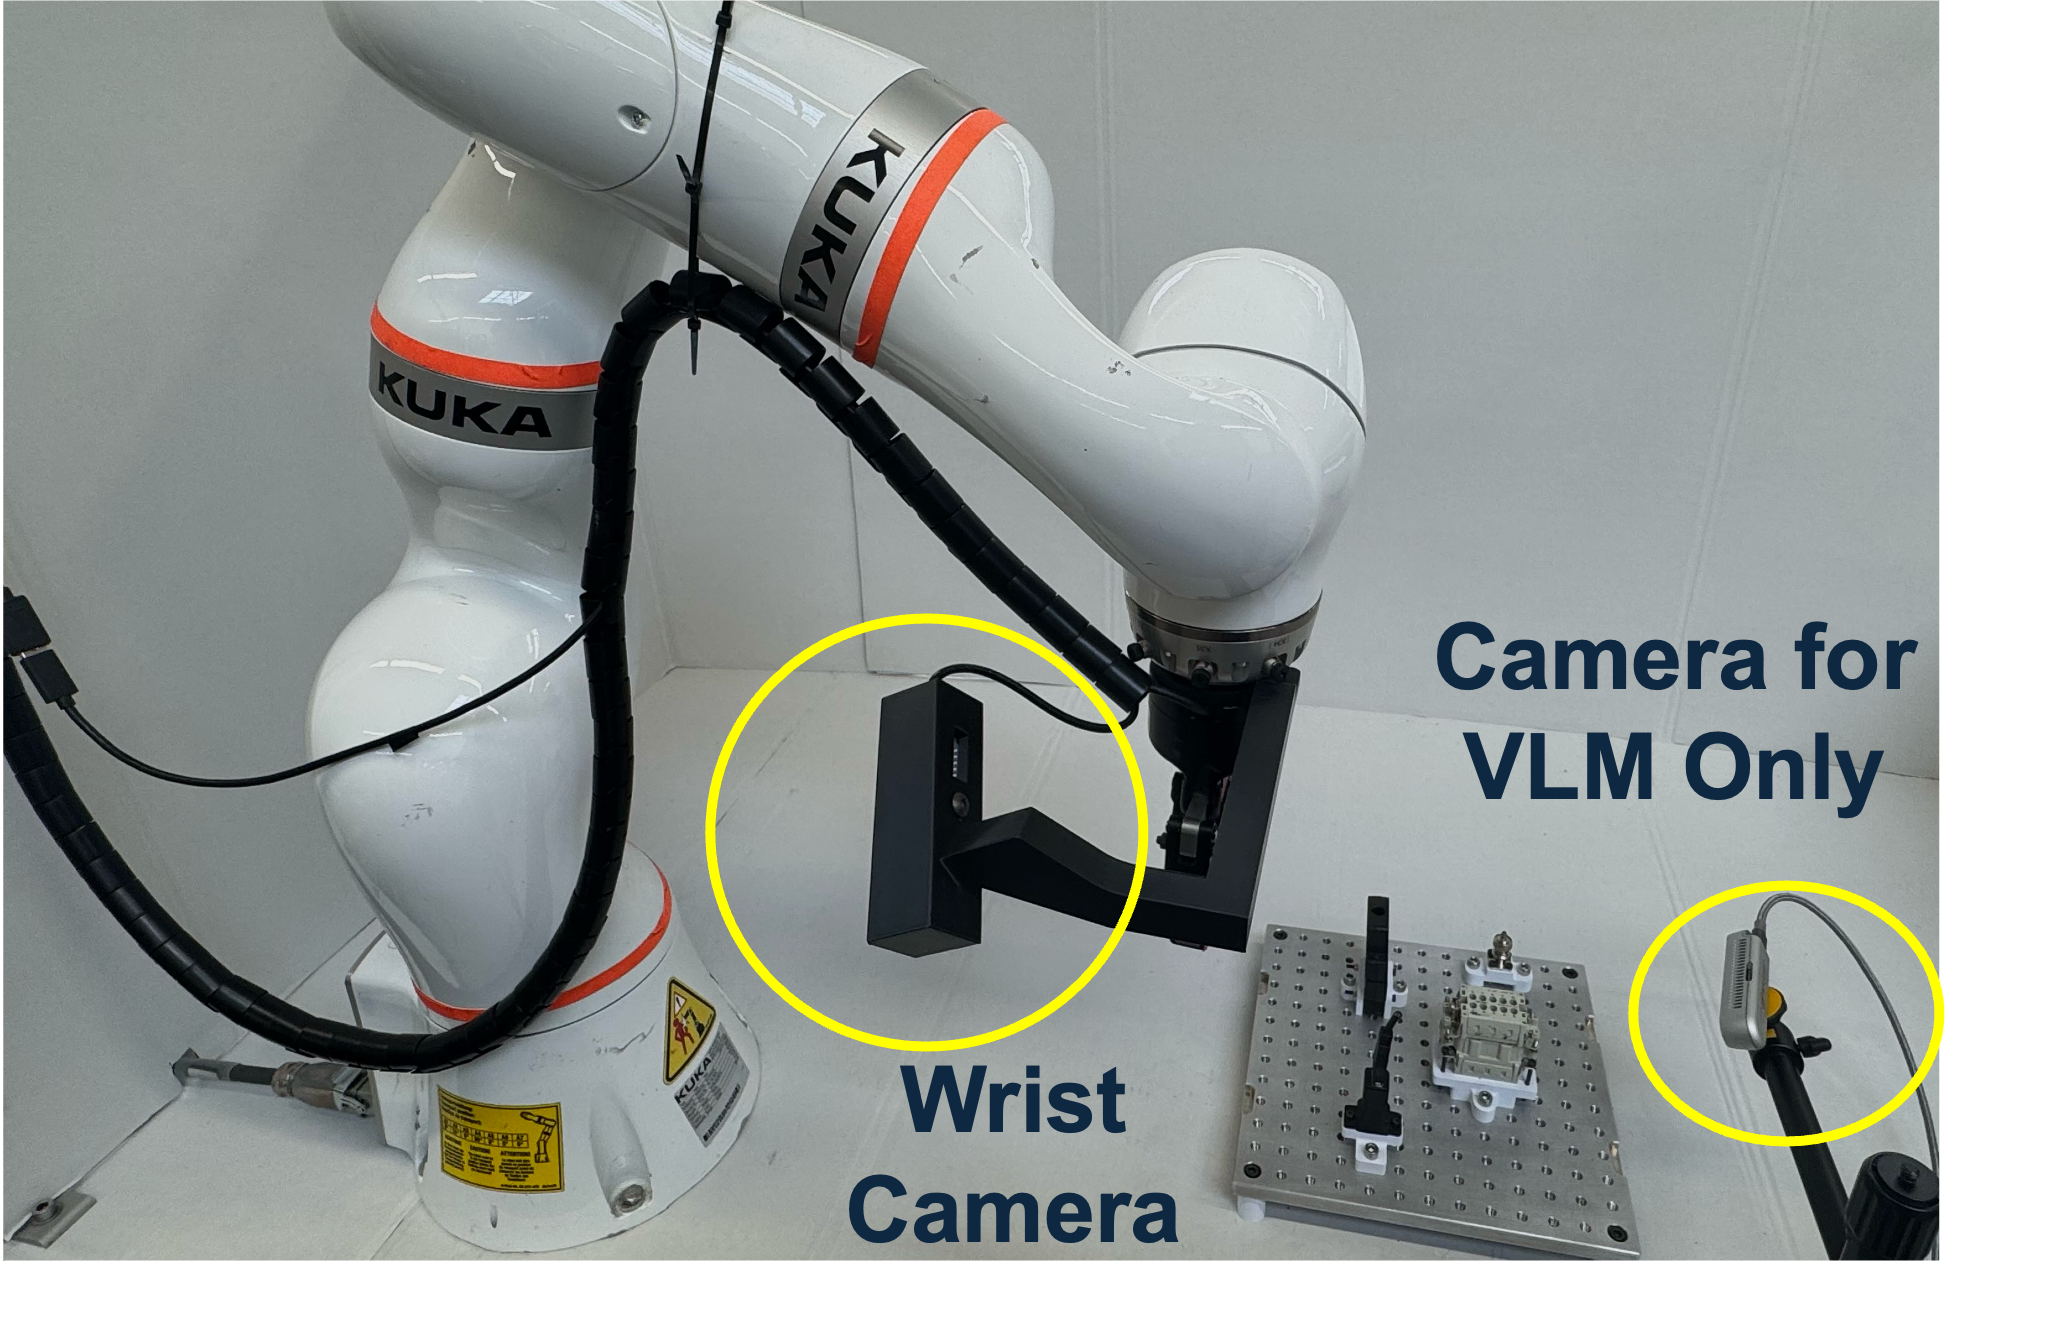
Hardware Setup
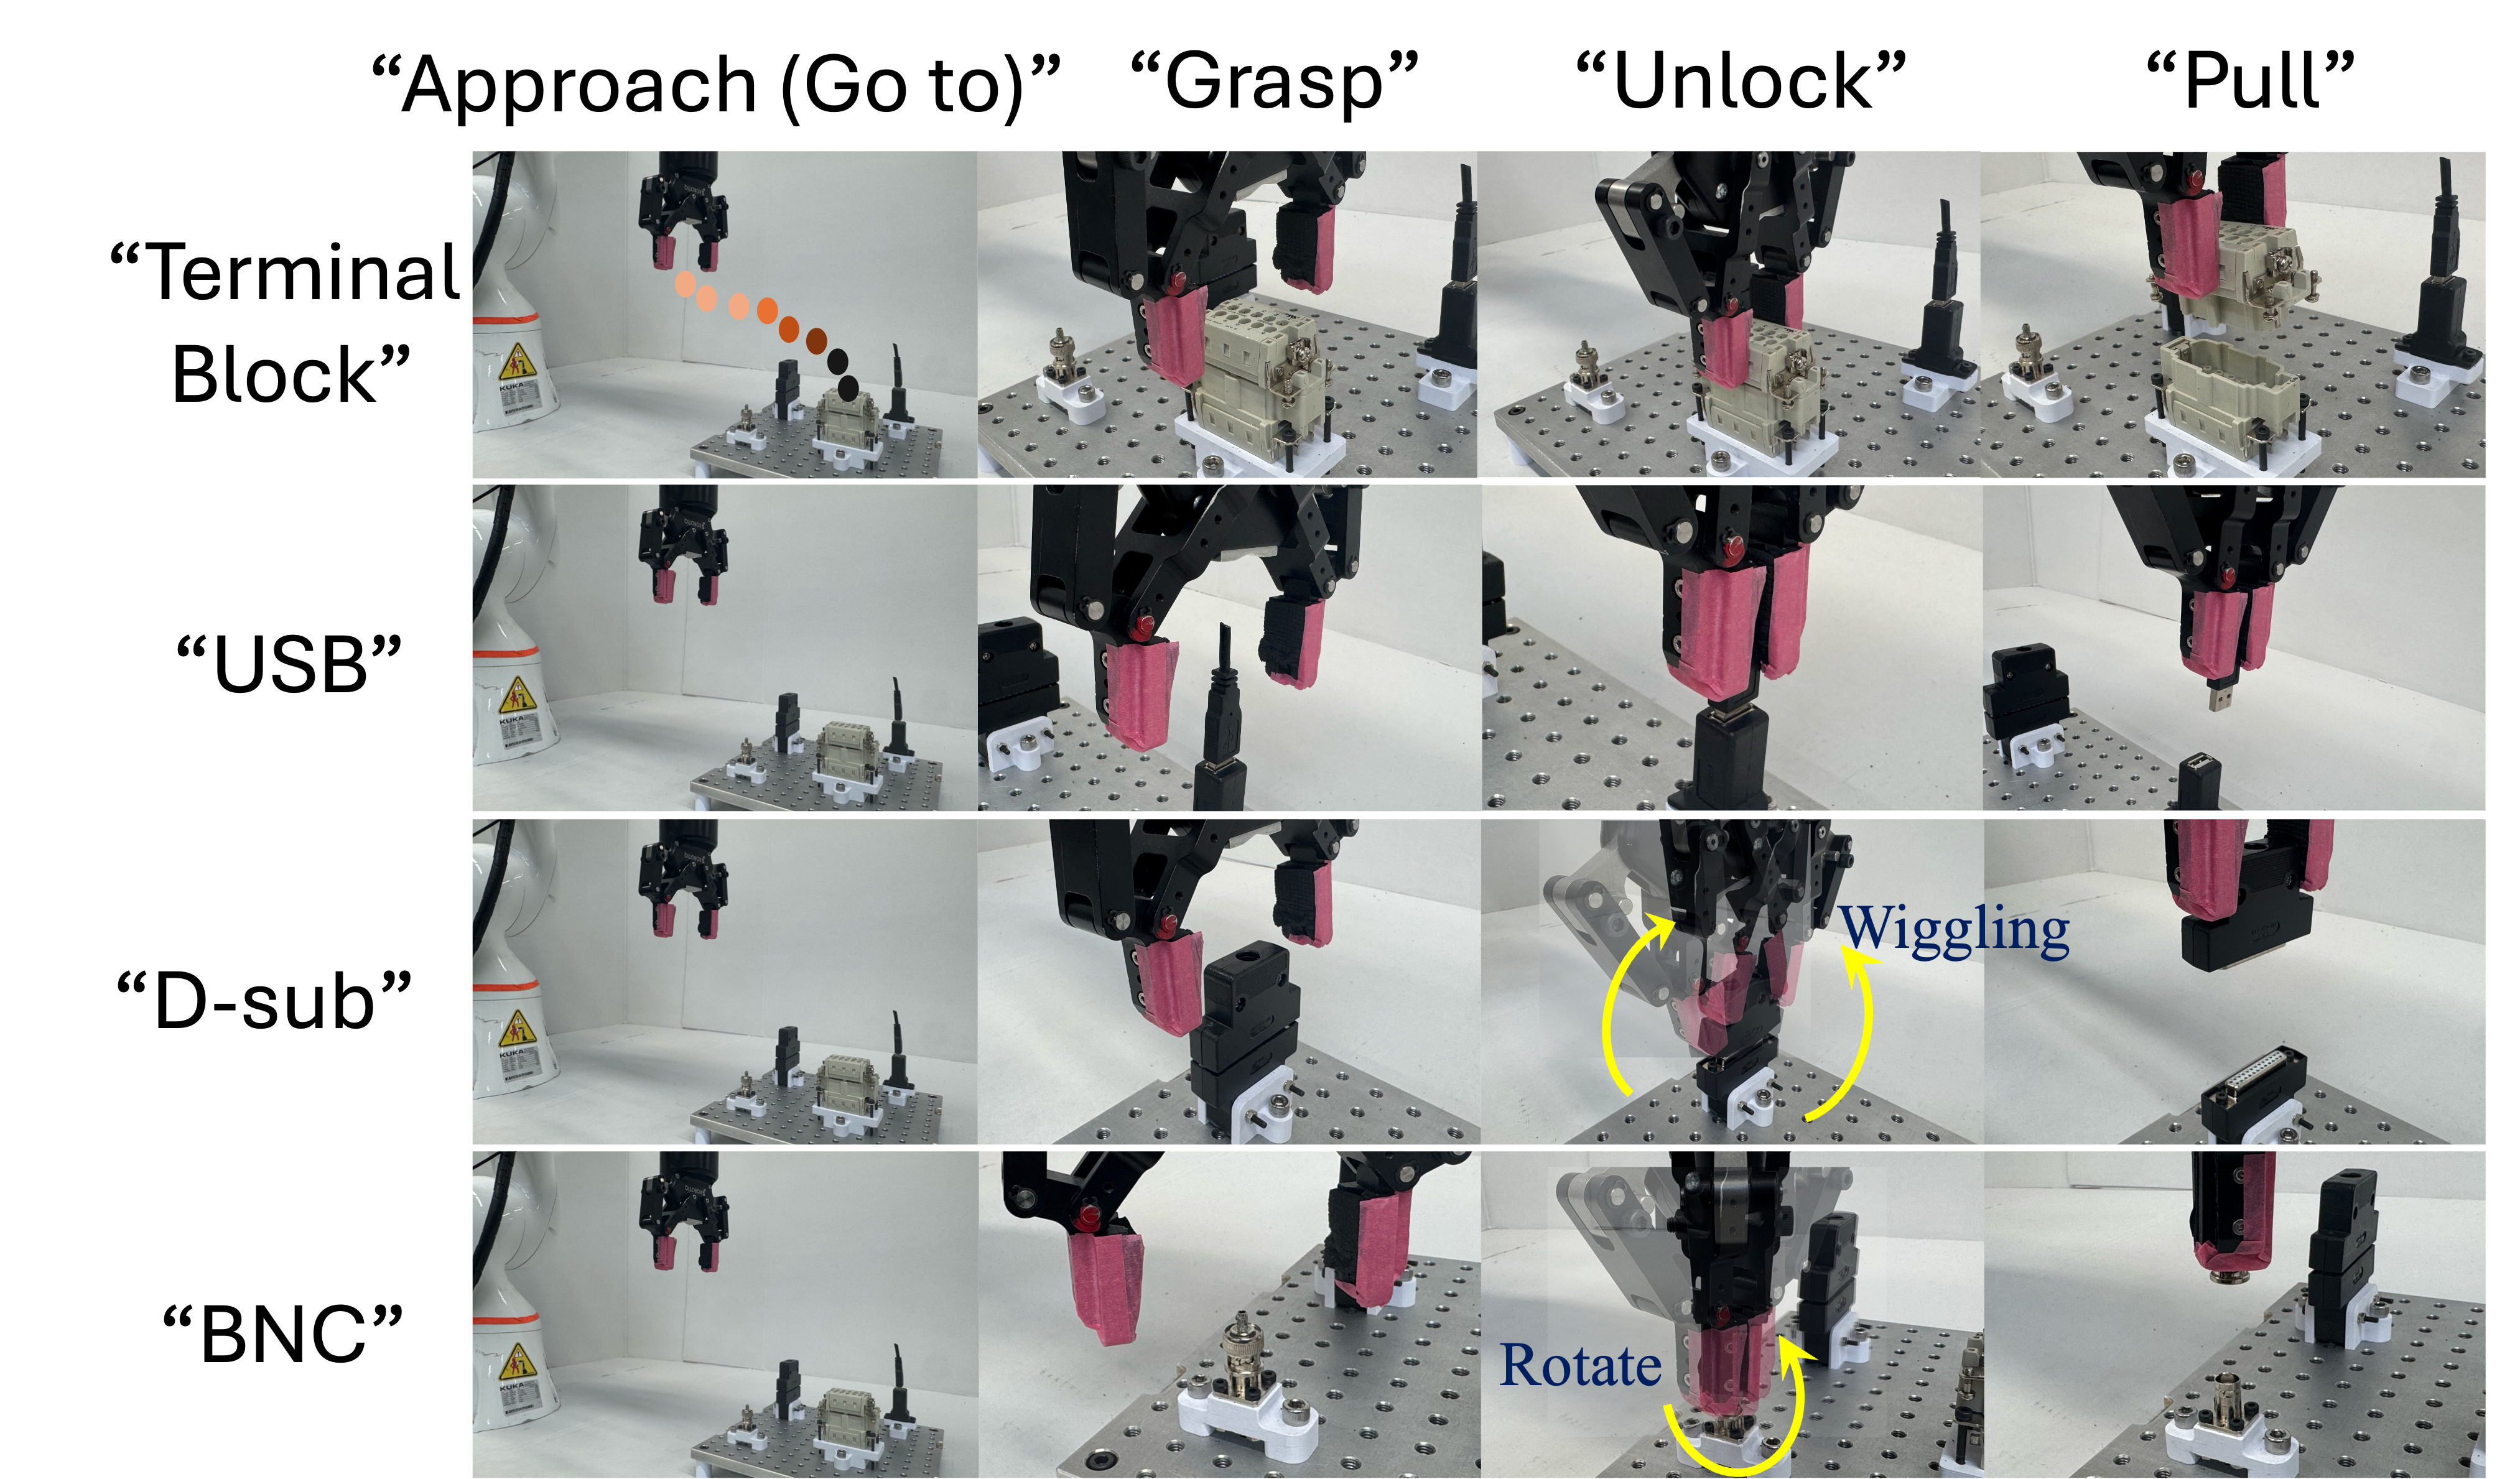
Connector Tasks
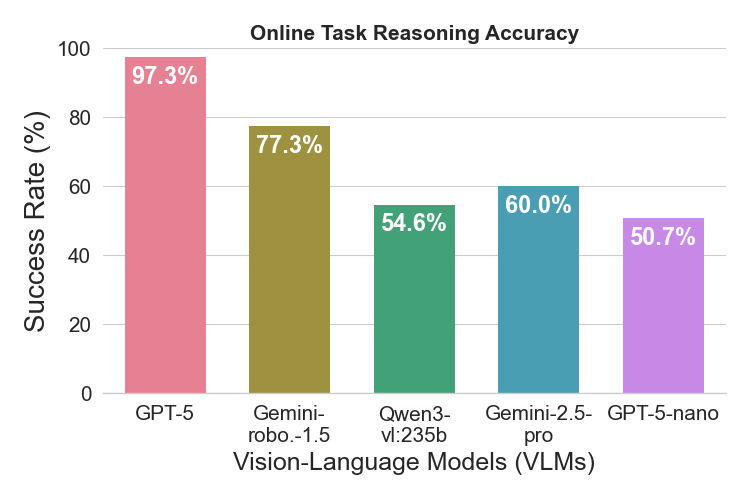
Accuracy of online proposals for the next sub-task.
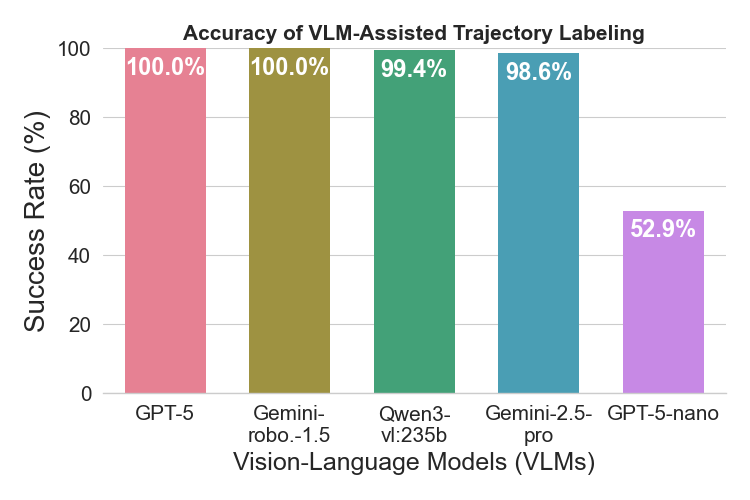
Sub-task accuracy on trajectory data evaluated across five VLMs.
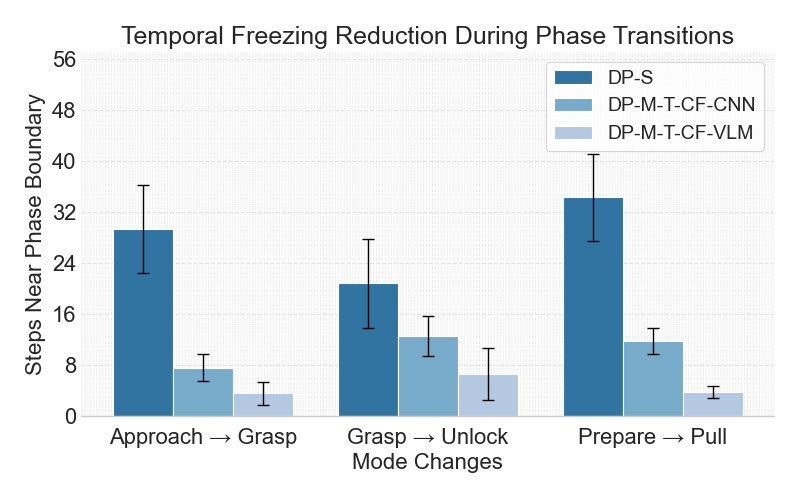
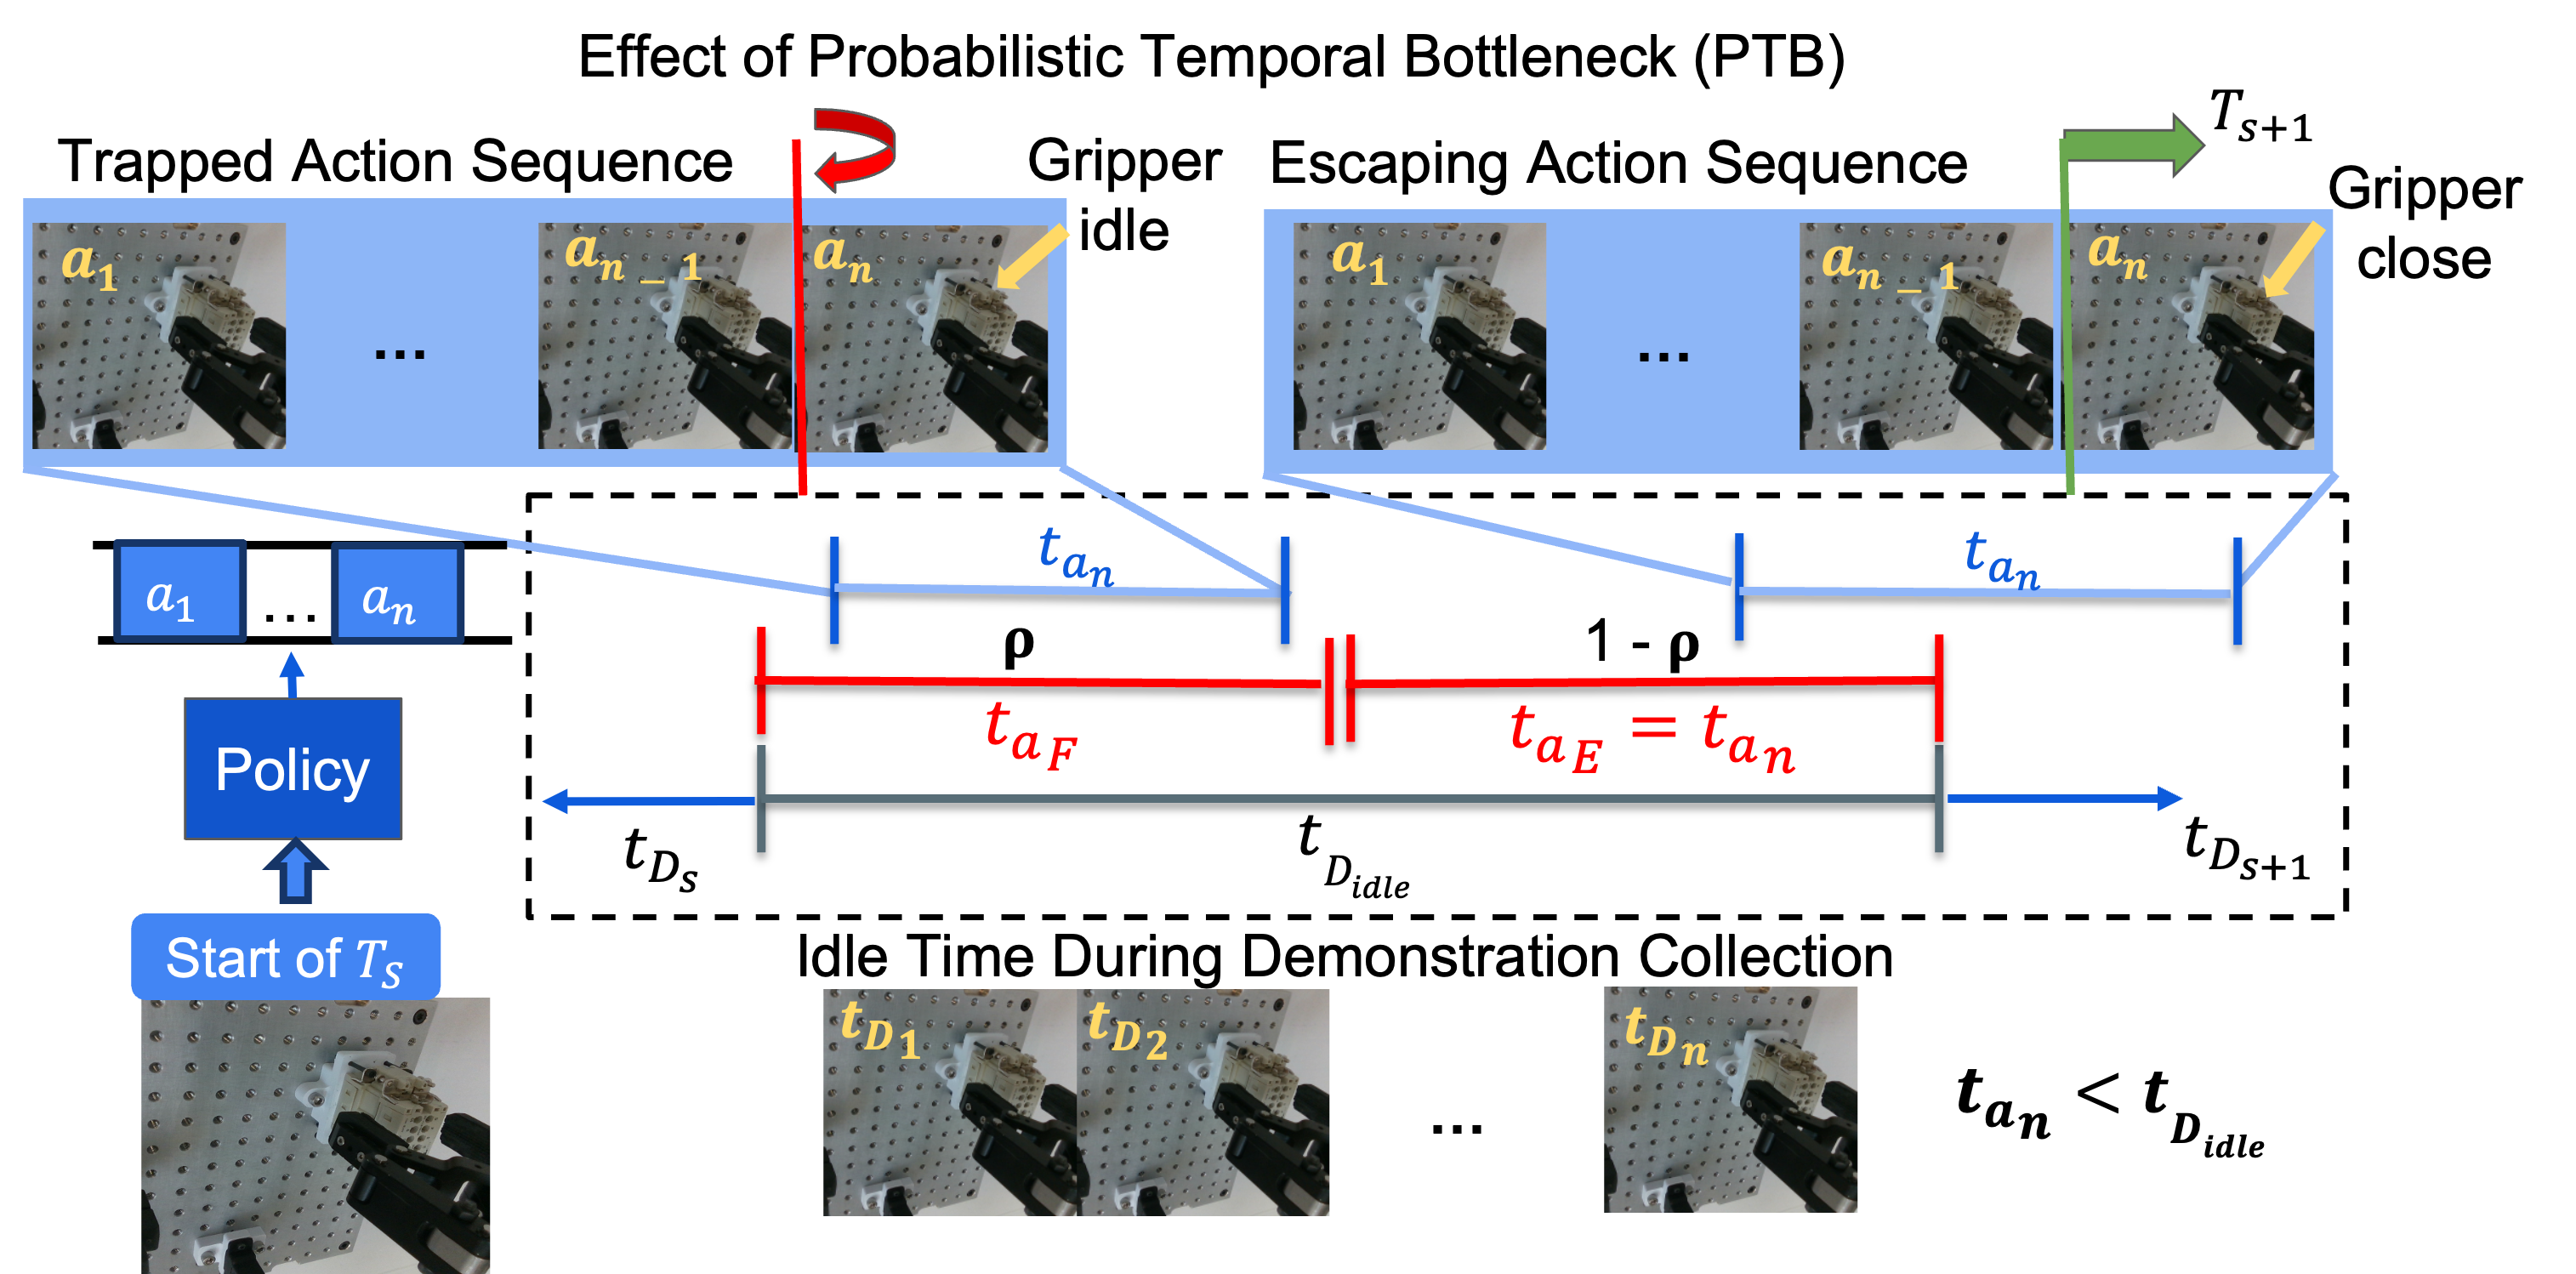
Action steps taken for mode switching.
| Method | Connector Removal Success Rates | Avg. Success Rate | |||
|---|---|---|---|---|---|
| D-Sub | USB | BNC | Terminal | ||
| DP-S | 0.65 | 0.60 | 0.45 | 0.65 | 0.59 |
| DP-M-C-CNN | 0.10 | 0.20 | 0.00 | 0.45 | 0.19 |
| DP-M-T-CF-RB | 0.45 | 0.65 | 0.55 | 0.95 | 0.65 |
| DP-M-T-CF-CNN | 0.95 | 1.00 | 0.75 | 1.00 | 0.93 |
| DP-M-T-CF-VLM-V1 | 0.85 | 0.90 | 0.60 | 0.90 | 0.83 |
| DP-M-T-CF-VLM-V2 | 0.95 | 1.00 | 0.80 | 1.00 | 0.94 |
Task success rate comparison.
| Method | USB Hub | Power Cable | Magnetic | Velcro |
|---|---|---|---|---|
| CNN | 0.40 | 0.50 | 0.30 | 0.00 |
| VLM-V2 | 0.90 | 0.90 | 0.70 | 0.60 |
Task success rates on held-out connector mechanisms and configurations.
| Model | Success Rate (%) |
|---|---|
| DiT (no Cross-Attention, no CF Loss) | 43.3 |
| DiT + CF Loss | 66.6 |
| iT + CF Loss + Cross-Attention (Ours) | 100 |
Ablation: Success rate in object selection upon language command.

CF Hinge Loss behavior during training, compared with MSEs for correct and incorrect action-language pairs.
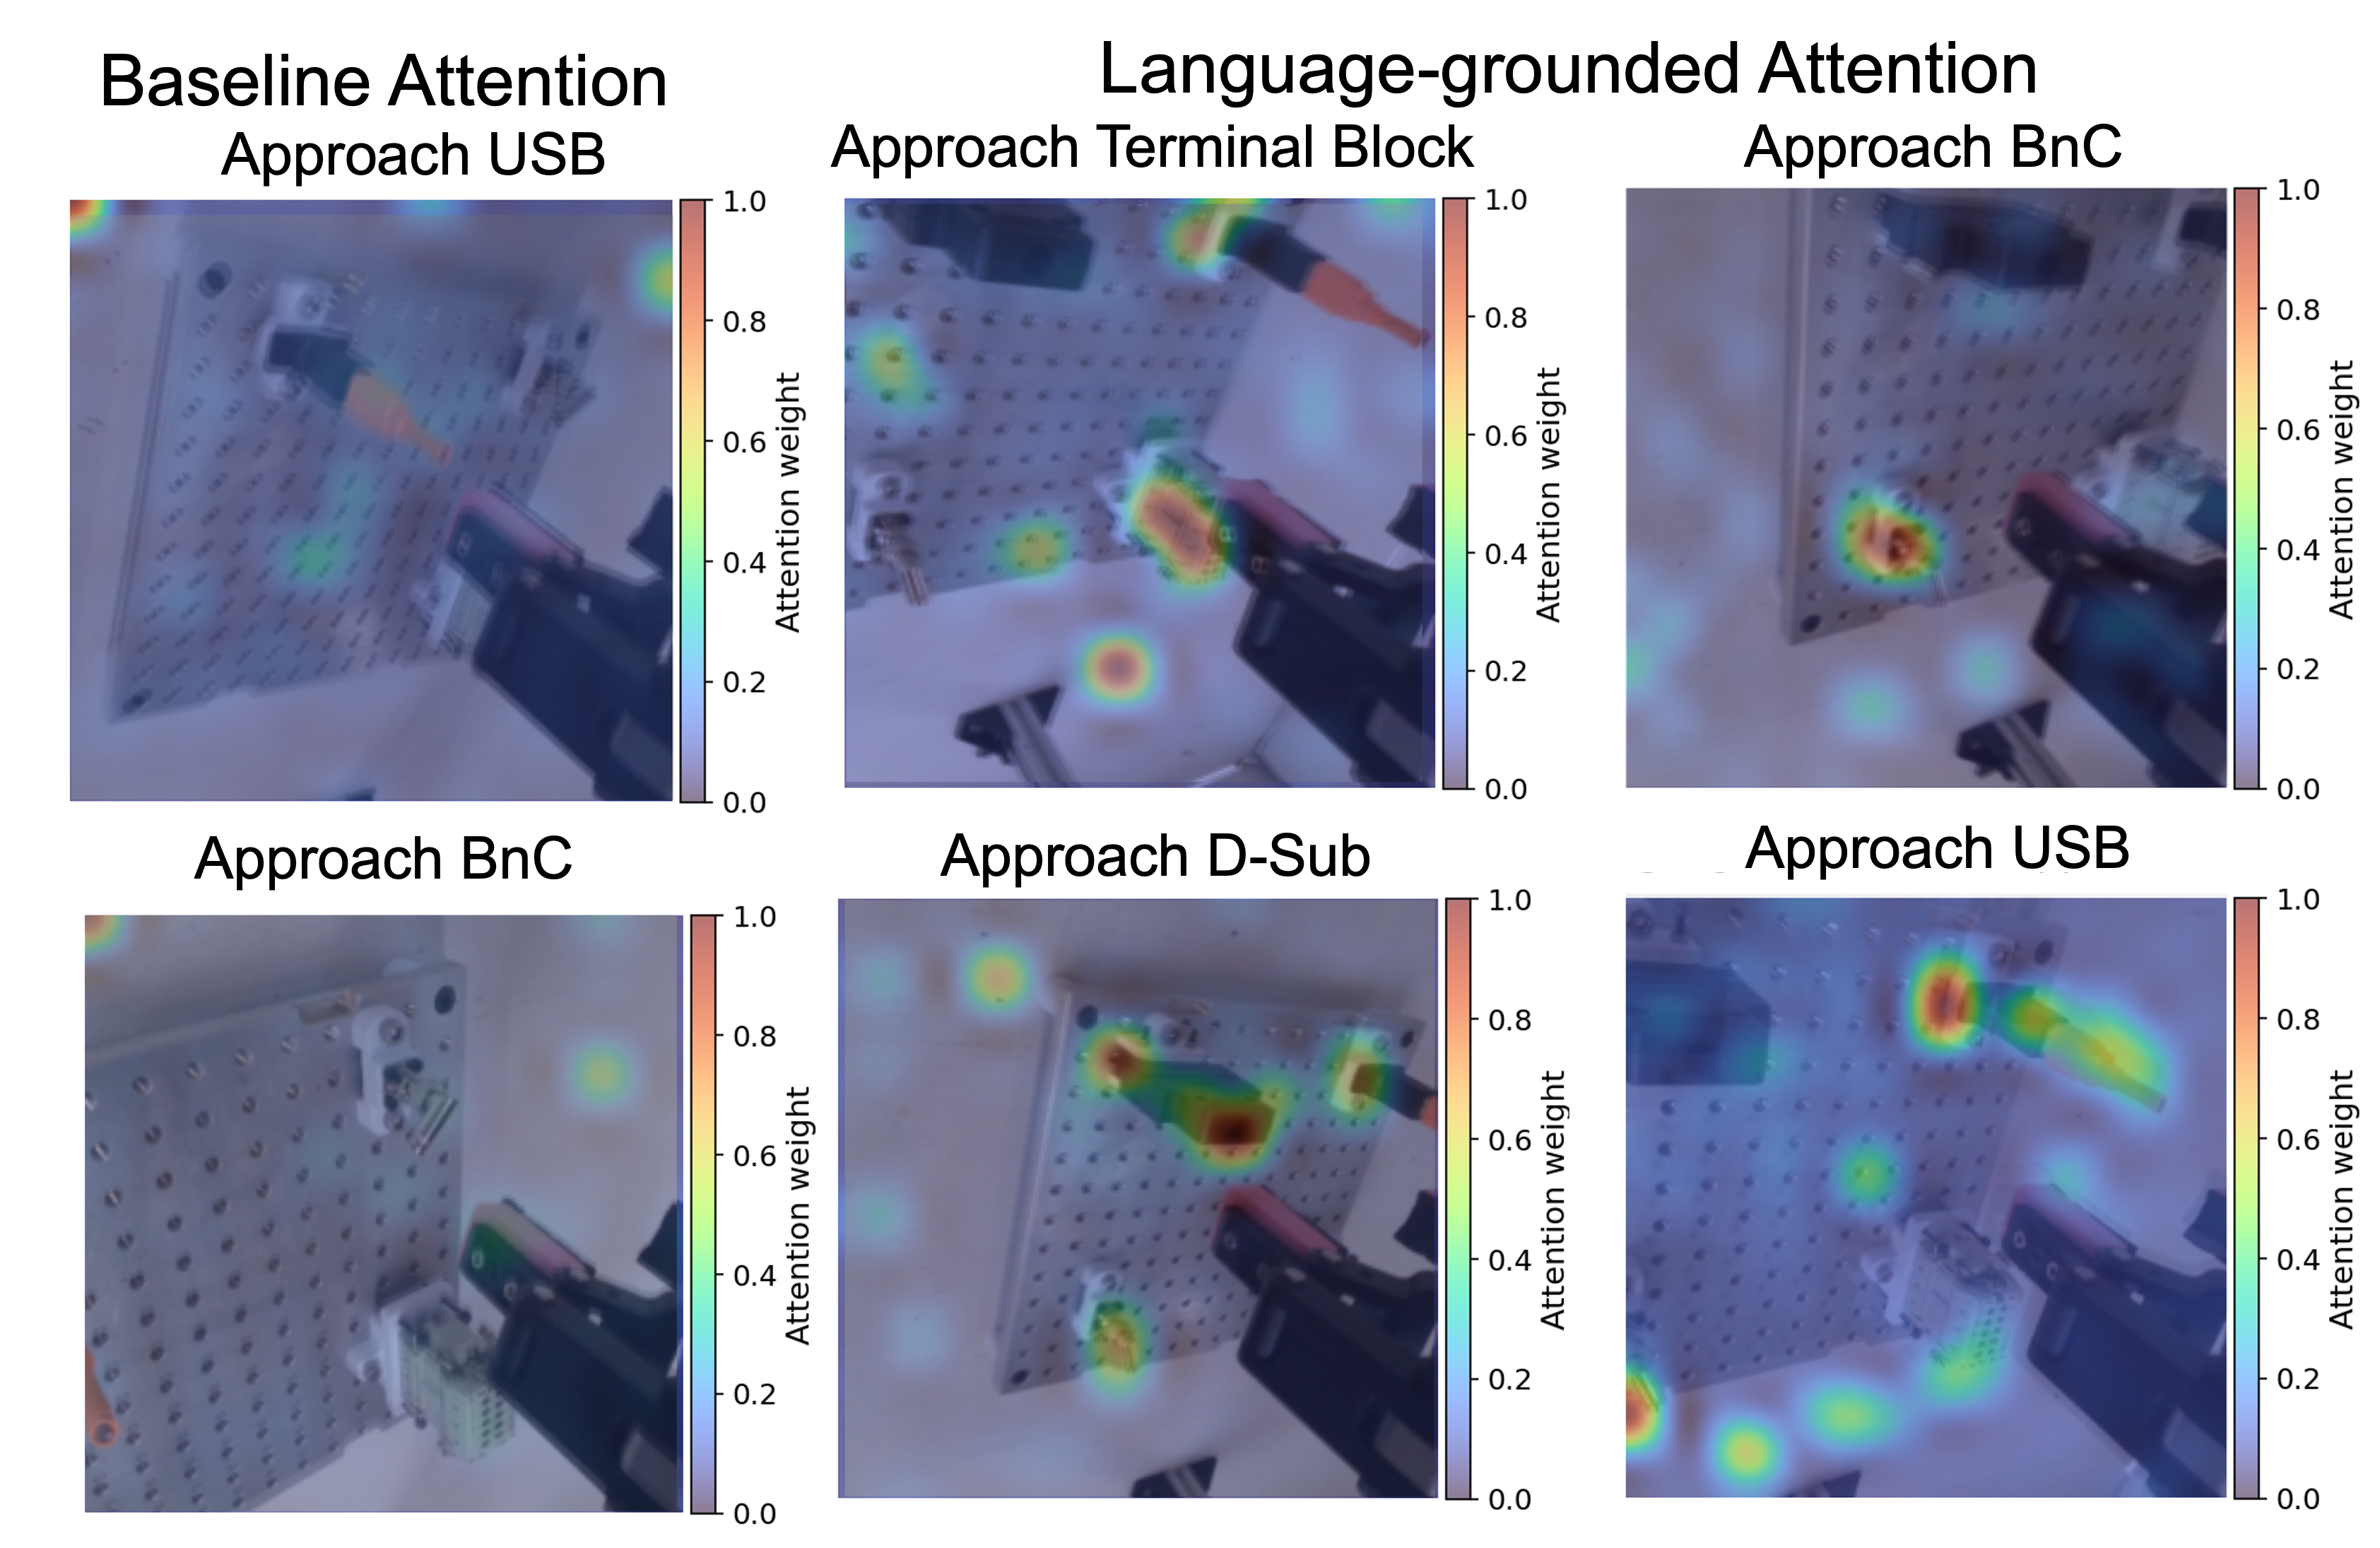
Visualization of the attention map during approach phase under different language commands.
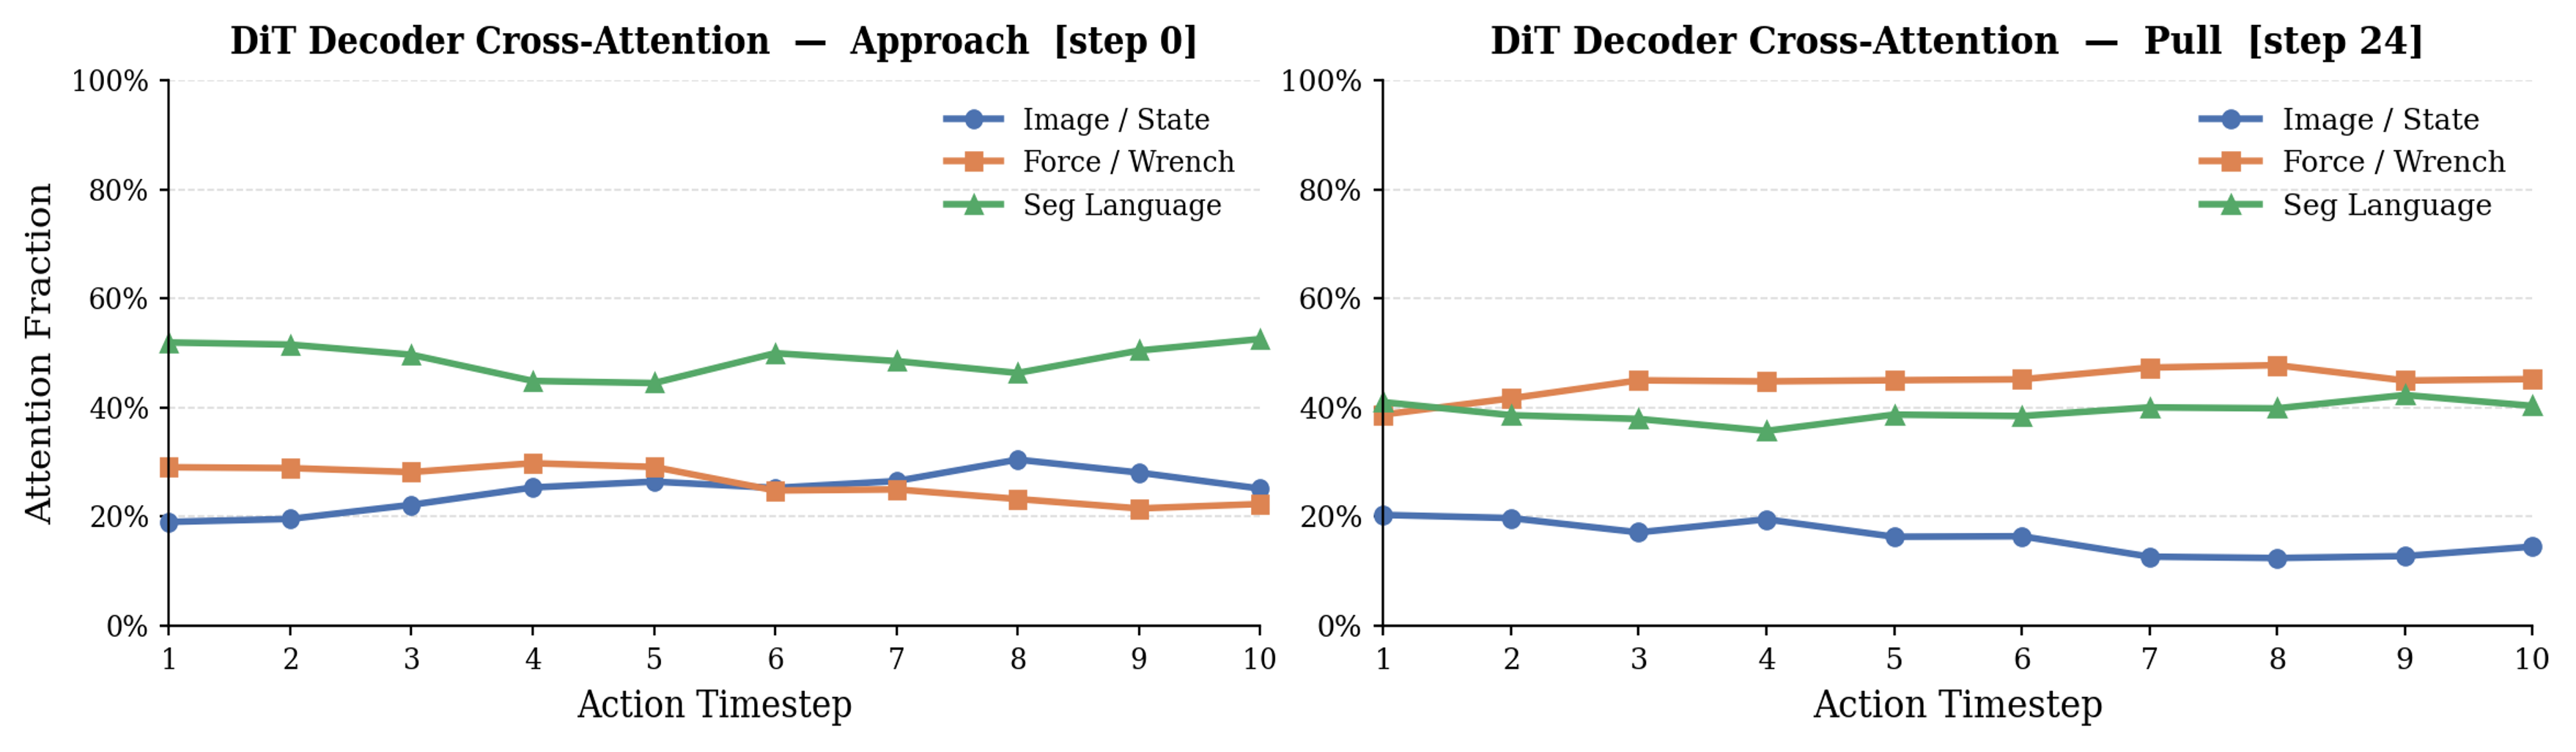
Attention weights assigned to different modalities during action prediction in the DiT policy.
TBD